-
-
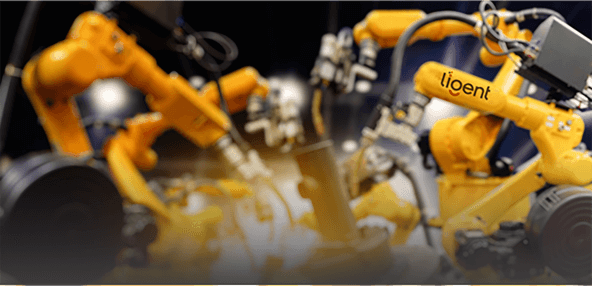
Welding robot
The hollow robot can reach 95% of the speed of Yaskawa robot.Support TIG/MIG/MAG welding process and laser welding processEuropean standard safety dou
-
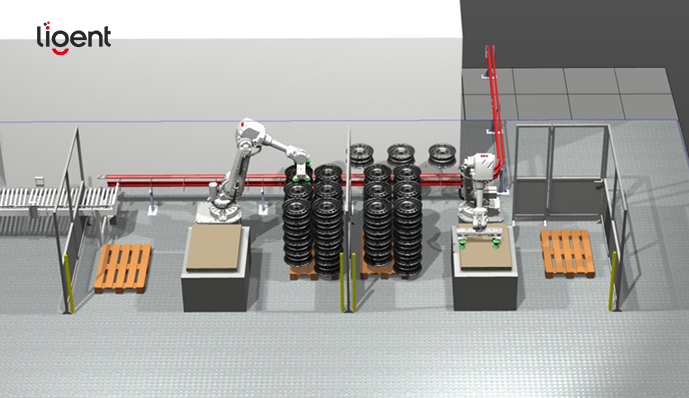
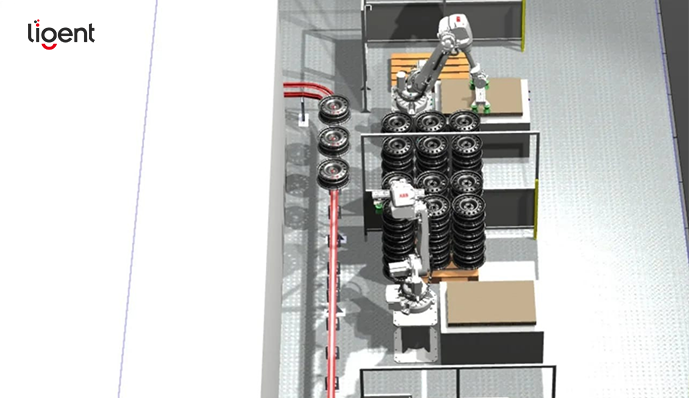
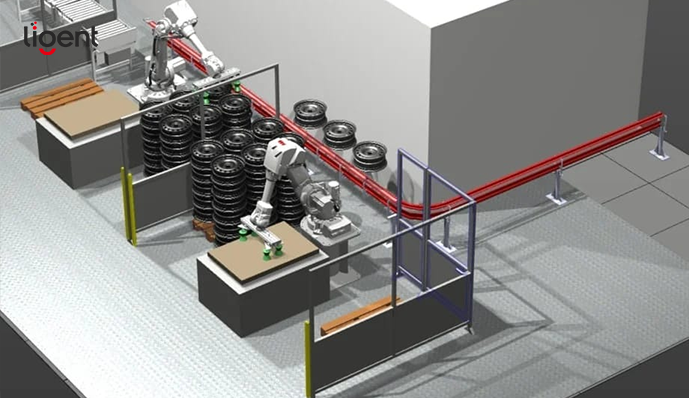
Handling robot
Load range from 3KG to 1600KG, protection grade IP67, higher speed, more reliable and richer
-
Scara robot
Accuracy +-0.01mm, door word (25mm * 300mm * 25mm) beat speed up to 0.48 secondsNo singular points, drag teaching, anti-collision, drag teaching, abso
-
Small 6 axis robot
Accuracy +-0.02mm, door word (25mm * 300mm * 25mm) beat speed up to 0.48 secondsNo singular points, drag teaching, anti-collision, high-speed emergenc
-
collaborative robot
SGS CE certification, CR certification and ISO9001 enterprise certificationSupport common processes such as welding, handling, and palletizing.Europea
-
Positioner and linear rail
Positioners, gun cleaning stations, overhead rails, ground rails and other equipment
-
More equipment
Positioner and rotary table ; Linear rail , Welding platform, Welding torch , Gripper, Torch cleaning station, Water tank
The hollow robot can reach 95% of the speed of Yaskawa robot.Support TIG/MIG/MAG welding process and laser welding processEuropean standard safety dou -
ST10-C1488K
4 axis 10kg payload -
ST45-1870BK
6 axis 45kg payload -
ST35-1870BK
6 axis 35kg payload -
ST20-2100BK
6 axis 20kg payload -
ST80-2050A
6 axis 80kg payload -
ST30-1831A
6 axis 30kg payload -
ST180-3150A
4 axis 180kg payload -
ST210-3100A
6 axis 210kg payload -
ST210-2700A
6 axis 210kg payload -
ST500-C3200
4 axis 500kg payload -
ST120-2230A
6 axis 120kg payload -
ST30-C1750K
4 axis 30kg payload -
ST35-C1900Y
6 axis 35kg payload -
ST360-2655A
6 axis 360kg payload -
ST500-3100
6 axis 210kg payload
-
Positioner DWP-P
400MM/500MM/600MM 200KG/500KG/1000KG -
Positioner DWP-C
400MM/400MM/600MM 200KG/500KG/1000KG -
Positioner DWP-L
400MM/500MM/600MM 500KG/1000KG/2000KG -
Positioner SWP-P
200KG/500KG 300MM/400MM -
Positioner SWP-Z
200KG/500KG 600MM -
Positioner SWP-ZW
500KG/1000KG 1200MM/1500MM -
Positioner TWP-C
1200MM/1500MM 500KG/1000KG -
Positioner TWP-S
500KG/1000KG 1200MM/1800MM -
Light rail
2-30M 0-60m/min -
Heavy rail
2-30M 0-60m/min
-
Welding robot
-
Industry overview

The robot load ranges from 6KG to 3200KG, with high speed and high precision; because of its innovative, efficient and competitive solutions; it is recognized by users around the world and has accumulated a large number of application cases -
Car parts
Automobile assembly parts processing -
Plastic chemical industry
Give you higher economic benefits -
3C electronics
Leading the reform of 3C industry -
Food packaging
Hygienic, safe and reliable -
Construction Machinery
Accurate repeat positioning -
Pharmaceutical
Ensure production safety and stability -
Warehouse Logistics
Warehouse Logistics -
New energy
New energy -
Construction machinery
Construction machinery
-
-
Application overview
Through fine classification and higher core computing, the maximum operating speed has broken through to 700 /s; the device speed has stable, fast and efficient performance regardless of long-distance or short-distance, and has IP65 protection level -
Vision
Rich visual system -
Dispensing
LIGENT robot dispensing -
Stamping
Repeatable accuracy positioning -
Polishing
Surface treatment process -
Cutting
Robots replace high-risk jobs -
Spraying
Excellent spray painting proces -
CNC Processing
Efficient CNC industry automati -
Palletizing
6KG-1400KG for your choice -
Welding
ARC, TIG, Laser, MIG, Ultrasoni -
Bending
Multi-axis flexibility -
Assembly
Make assembly easier
-
-
Service and Support
LIENGT robot has been focusing on manufacturing, research and development, and sales of industrial robots for ten years, creating value for you with professional
-
About Us
LIGENT robot is a provider of industrial robots, core components and industrial automation solutions. The companys industrial robots have been successfully appli -
About LIGENT
We are committed to creating a positive and dynamic work environment -
Blog
We are committed to creating a positive and dynamic work environment -
Case
We are committed to creating a positive and dynamic work environment -
Find a dealer
Enter the distributor's company name (full name or field) to verify that it is an
-